D'Onofrio model (binary variant): Difference between revisions
ClemensZeile (talk | contribs) No edit summary |
ClemensZeile (talk | contribs) |
||
| Line 46: | Line 46: | ||
<gallery caption="Reference solution plots" widths="180px" heights="140px" perrow="2"> | <gallery caption="Reference solution plots" widths="180px" heights="140px" perrow="2"> | ||
Image: | Image:DonofrioRelaxed 6000 60 1.png| Optimal relaxed differential states determined by an direct approach with ampl_mintoc (Radau collocation) and <math>n_t=6000, \, n_u=100</math>. | ||
Image:DonofrioCIA 6000 60 1.png| Optimal binary differential states determined by an direct approach (Radau collocation) with ampl_mintoc and <math>n_t=6000, \, n_u=100</math>. The relaxed controls were approximated by Combinatorial Integral Approximation. | Image:DonofrioCIA 6000 60 1.png| Optimal binary differential states determined by an direct approach (Radau collocation) with ampl_mintoc and <math>n_t=6000, \, n_u=100</math>. The relaxed controls were approximated by Combinatorial Integral Approximation. | ||
</gallery> | </gallery> | ||
== Source Code == | == Source Code == | ||
Revision as of 15:33, 11 January 2018
| D'Onofrio model (binary variant) | |
|---|---|
| State dimension: | 1 |
| Differential states: | 4 |
| Discrete control functions: | 4 |
| Path constraints: | 2 |
This site describes a D'Onofrio model variant with four binary controls instead which of only two continuous controls. The continuous controls are replaced via the outer convexifacation method.
Mathematical formulation
For the optimal control problem is given by
Parameters
The parameters and scenarios are as in D'Onofrio_chemotherapy_model, the new fixed parameters are
Reference Solutions
If the problem is relaxed, i.e., we demand that be in the continuous interval instead of the binary choice , the optimal solution can be determined by using a direct method such as collocation or Bock's direct multiple shooting method.
The optimal objective value of scenario 2 of the relaxed problem with is . The objective value of the binary controls obtained by Combinatorial Integral Approimation (CIA) is . The binary control solution was evaluated in the MIOCP by using a Merit function with additional Mayer term
.
- Reference solution plots
-
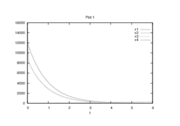 Optimal relaxed differential states determined by an direct approach with ampl_mintoc (Radau collocation) and .
-
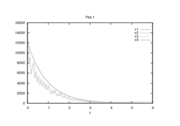 Optimal binary differential states determined by an direct approach (Radau collocation) with ampl_mintoc and . The relaxed controls were approximated by Combinatorial Integral Approximation.


Source Code
Model description is available in